Safe Diffusion Policies for Robot Learning
Investigating inference-time safety mechanisms for diffusion policies in long-horizon robot decision-making, with a PyTorch framework spanning navigation and manipulation.
•
1 min read
Investigating inference-time safety mechanisms for diffusion policies in long-horizon robot decision-making, with a PyTorch framework spanning navigation and manipulation.
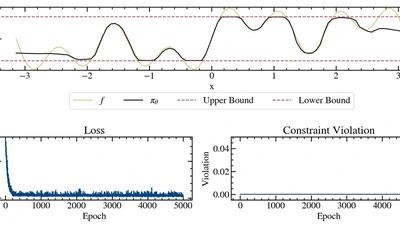
Safety-critical learning requires policies that improve performance without leaving the safe operating regime. We study constrained policy learning where model parameters must …

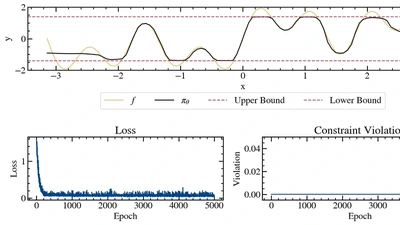
Proposed a sampling-based weight-space projection framework for enforcing safety constraints during policy updates.
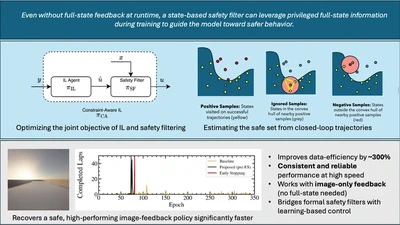
Guaranteeing constraint satisfaction is a challenging problem in imitation learning (IL), especially when the task involves operating at the handling limits of the system. While …
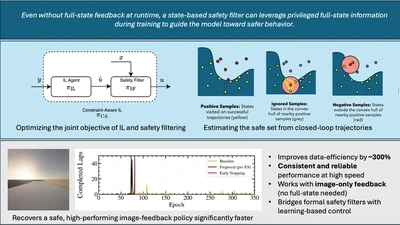
Designed a constraint-aware imitation learning framework incorporating an actor-critic structure for explicit safety modeling.