Interleaved Projected Gradient Descent for Safe Imitation Learning
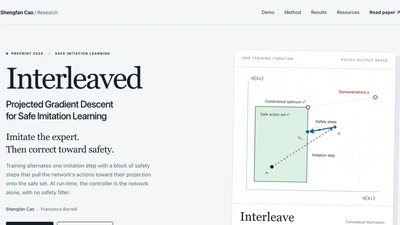
We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …

We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …