Interleaved Projected Gradient Descent for Safe Imitation Learning
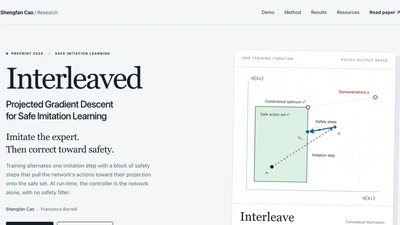
We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …

We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …
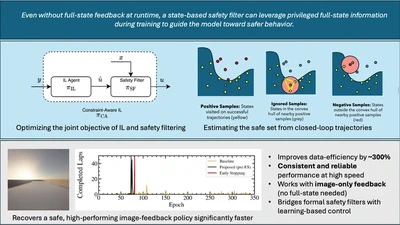
Guaranteeing constraint satisfaction is a challenging problem in imitation learning (IL), especially when the task involves operating at the handling limits of the system. While …
This paper presents the real-time implementation and experimental validation of a regulation-aware, game-theoretic motion planning framework for autonomous racing. The framework …
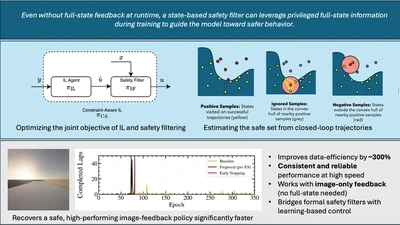
Designed a constraint-aware imitation learning framework incorporating an actor-critic structure for explicit safety modeling.
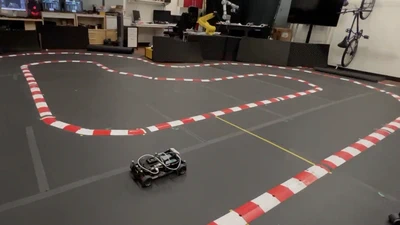
Developed a CNN-based end-to-end controller for high-speed autonomous racing using RGB camera input and velocity feedback.