Interleaved Projected Gradient Descent for Safe Imitation Learning
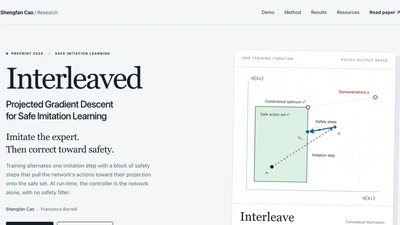
We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …

We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …
We study visual domain transfer for end-to-end imitation learning in a realistic and challenging setting where target-domain data are strictly off-policy, expert-free, and scarce. …
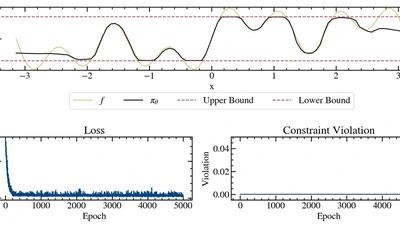
Safety-critical learning requires policies that improve performance without leaving the safe operating regime. We study constrained policy learning where model parameters must …
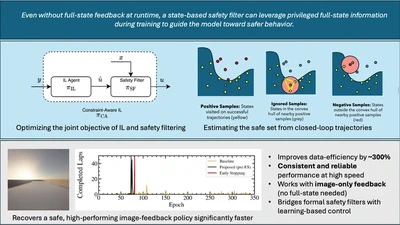
Guaranteeing constraint satisfaction is a challenging problem in imitation learning (IL), especially when the task involves operating at the handling limits of the system. While …
This paper presents the real-time implementation and experimental validation of a regulation-aware, game-theoretic motion planning framework for autonomous racing. The framework …