Safe Imitation Learning at Handling Limits
Nov 1, 2024
·
1 min read
Principal Researcher (Nov 2024 — Feb 2025)
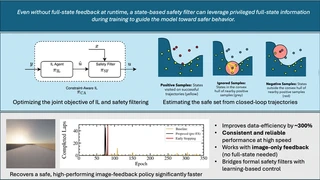
- Designed a constraint-aware imitation learning framework incorporating an actor-critic structure for explicit safety modeling.
- Improved training efficiency by 150% and reduced collision rates by 60% at the vehicle’s dynamic handling limits in CARLA simulation.
- Integrated reachability-based safety filters into the training pipeline, enabling safe policy generalization.
- Oral presentation at IEEE IROS 2025 for this work: “A Simple Approach to Constraint-Aware Imitation Learning with Application to Autonomous Racing”.
Tech: PyTorch, CasADi, CARLA, RL, MPC, optimization, safety-aware learning.

Authors
Shengfan Cao
(he/him)
PhD Researcher in Autonomous Driving & Robotics
UC Berkeley Ph.D. candidate developing safe, machine-learning-based prediction, planning, and control systems for autonomous vehicles. First-author IEEE IROS oral presenter with 4+ years across machine learning, planning, and controls, spanning PyTorch research, CARLA evaluation, embedded-robot deployment, and C++ production planner integration.