Trajectory Optimization & Planning at DiDi Research America
Re-architected a production C++ trajectory-optimization solver and formulated MAP-based trajectory smoothing/denoising for an end-to-end planning model trained on 1.3B …
•
6 min read
Re-architected a production C++ trajectory-optimization solver and formulated MAP-based trajectory smoothing/denoising for an end-to-end planning model trained on 1.3B …
Investigating inference-time safety mechanisms for diffusion policies in long-horizon robot decision-making, with a PyTorch framework spanning navigation and manipulation.
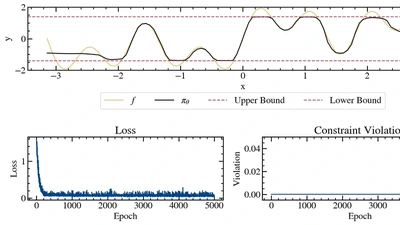
Proposed a sampling-based weight-space projection framework for enforcing safety constraints during policy updates.
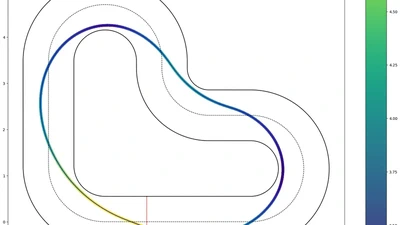
Developed a vehicle dynamics simulator based on dynamic bicycle model with standard gymnasium APIs and a CARLA connector.
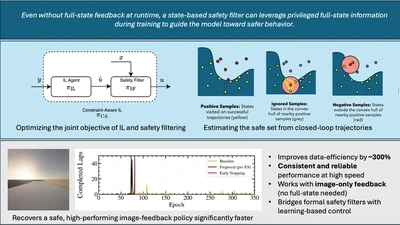
Designed a constraint-aware imitation learning framework incorporating an actor-critic structure for explicit safety modeling.
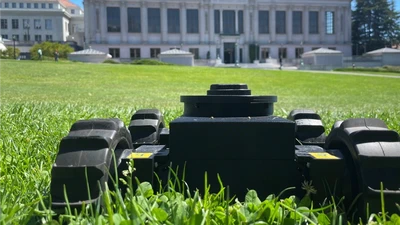
The Small Quick Integrated Ground Vehicle (SQUIG) vehicle is an autonomous ground vehicle currently under development by the Model Predictive Control (MPC) Lab at the University of …
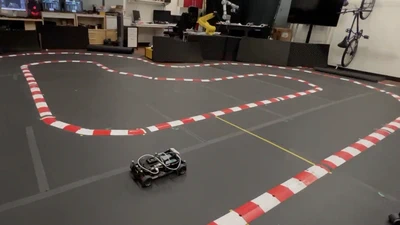
Developed a CNN-based end-to-end controller for high-speed autonomous racing using RGB camera input and velocity feedback.
Explored a goal-conditioned, data-driven MPC pipeline that learns transition costs between feasible states from closed-loop trajectories via imitation learning.
Co-implemented a ROS-based perception stack and connected it to an MPC planner and low-level controller to enable evasive maneuvers on a physical rover deployed in solar panel …
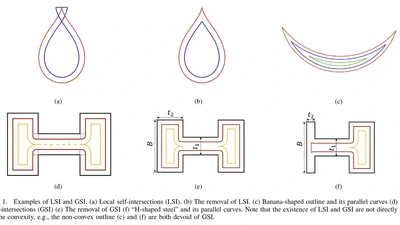
This project was conducted during my undergraduate studies as an exploration of geometric tool-path generation for planar coverage. Motivated by contour-parallel (offset curve) …