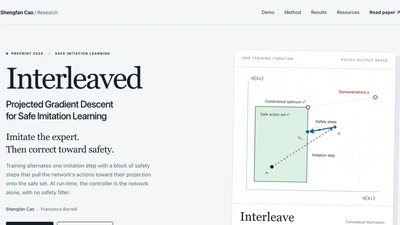
Interleaved Projected Gradient Descent for Safe Imitation Learning
We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …

 🚗
(he/him)
PhD Researcher in Autonomous Driving & Robotics
Ph.D. in Mechanical Engineering
2022-08-01
2027-05-31
University of California, Berkeley
B.S. in Mechanical Engineering
2018-09-01
2022-06-30
Tsinghua University
B.A. in Japanese Language and Literature
2017-08-23
2022-06-30
Tsinghua University
I am a PhD researcher at UC Berkeley specializing in safe learning, control theory, and end-to-end autonomy for robotic systems. My work bridges the gap between theoretical guarantees and real-world deployment, focusing on how large-scale data and physical constraints shape learning-based autonomous systems.
My current research highlights include:
I leverage tools like PyTorch, ROS 2, and convex optimization to build interpretable and reliable autonomy stacks. I am actively transitioning into industry to apply these principles to large-scale, safety-critical applications.
Please reach out to collaborate! 🚗
We propose an imitation-learning design for neural-network control policies under state and input constraints. Training alternates a standard imitation gradient step with a block …
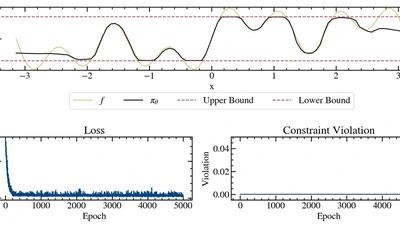
Safety-critical learning requires policies that improve performance without leaving the safe operating regime. We study constrained policy learning where model parameters must …
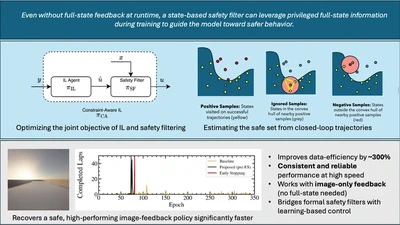
Guaranteeing constraint satisfaction is a challenging problem in imitation learning (IL), especially when the task involves operating at the handling limits of the system. While …
I am excited to share that my paper “A Simple Approach to Constraint-Aware Imitation Learning with Application to Autonomous Racing” has been accepted for oral presentation at IROS …